Naviground: autonomous vehicle perception

Máximo Fernández Núñez

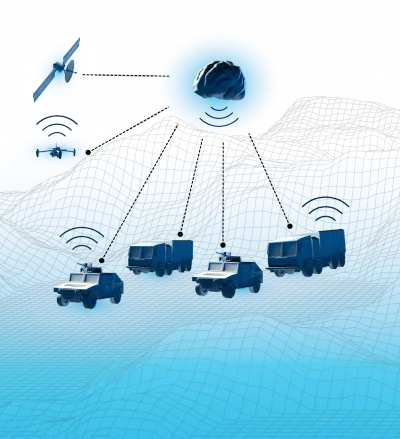
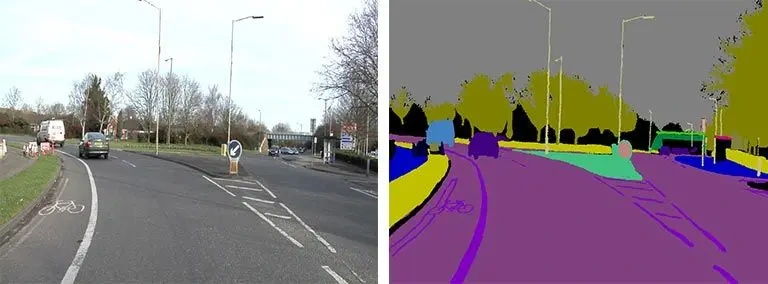
At Sener, I contributed to Naviground, an autonomous ground-vehicle perception system within a European consortium. My work covered semantic segmentation, object detection, classification and depth estimation. I created real and synthetic training datasets, fine-tuned vision models and built an annotation tool that reduced labelling time from hours to minutes per image. I optimised inference with TensorRT on NVIDIA AGX Orin, reducing latency and VRAM use by approximately 30% with around 2% accuracy loss. This portfolio describes my contribution to a team project; it does not claim sole ownership of the system. Public case study: https://www.maximofn.com/naviground
Like this project
Posted Oct 8, 2026
My contribution at Sener: autonomous-vehicle perception, real/synthetic datasets and TensorRT optimisation on NVIDIA AGX Orin. Team project.