
ROV Digital Twin — Autonomous Underwater Robot Simulation (Python + AI)
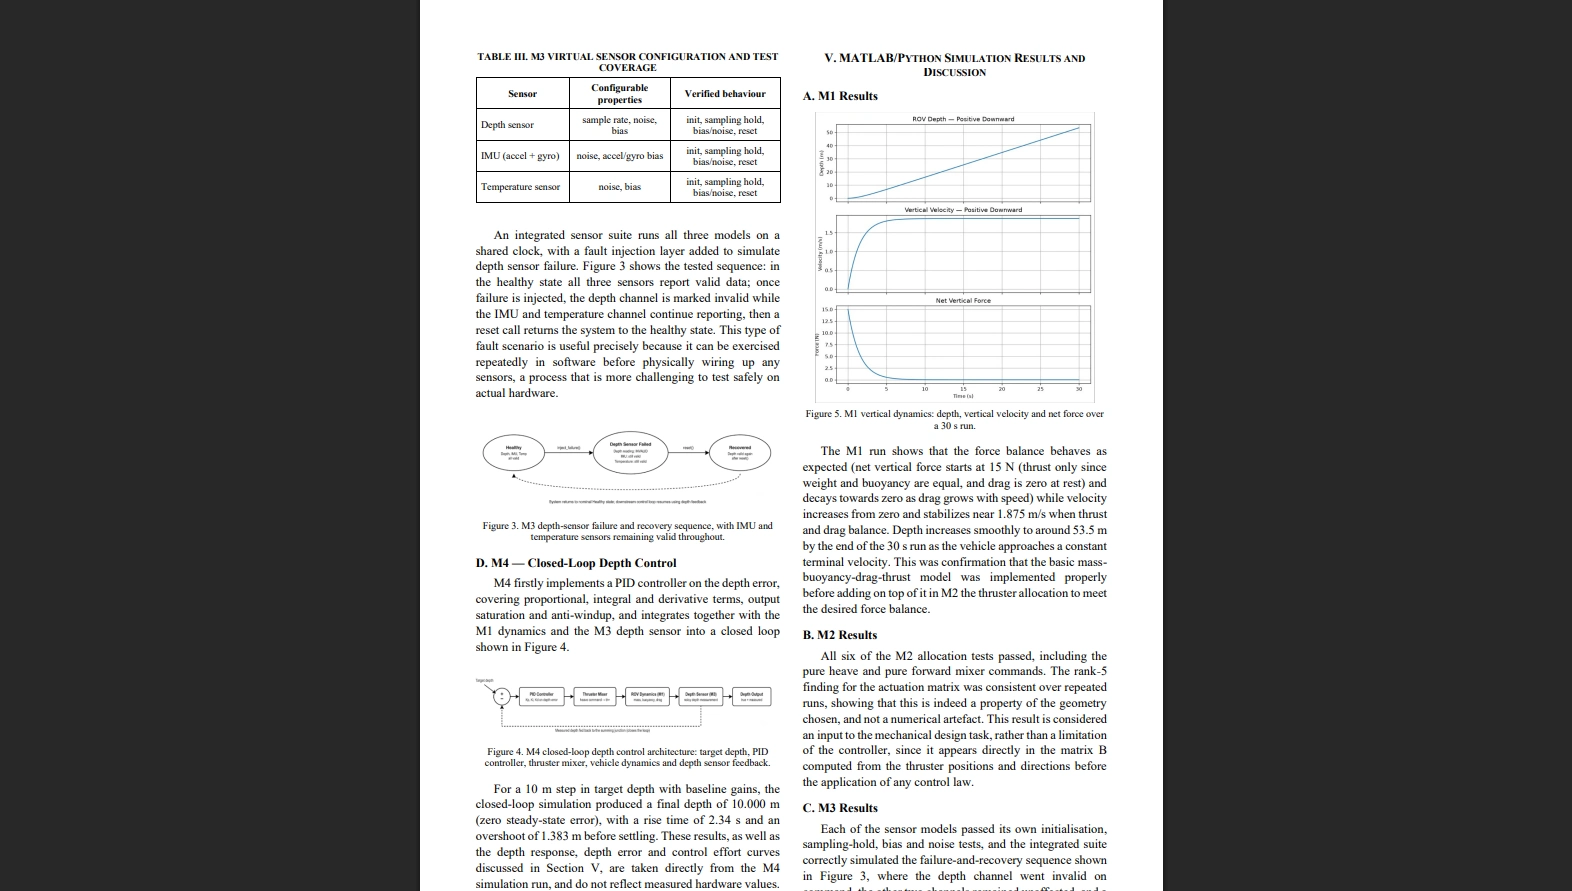
ROV Digital Twin — Autonomous Underwater Robot Simulation (Python + AI)Built a complete Digital Twin for a 6-thruster underwater ROV entirely in Python before any hardware was assembled — simulating vehicle physics, thruster control, sensor behaviour and PID depth control across 4 verified stages.
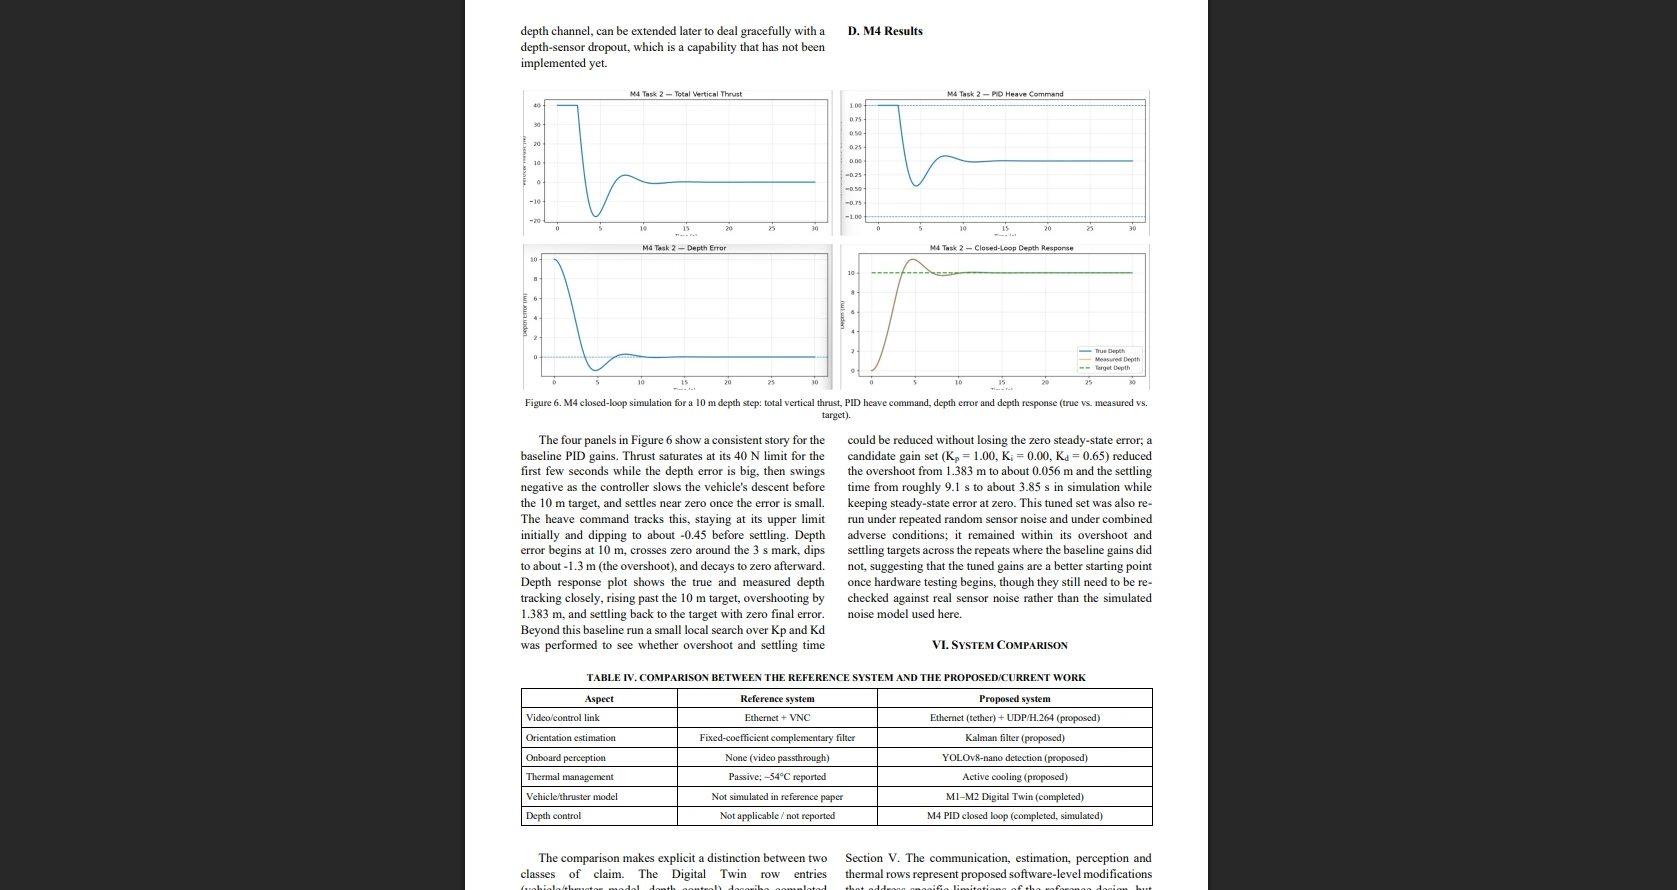
The simulation achieved zero steady-state depth error with a 10m step command, identified a rank-5 thruster geometry limitation early (saving hardware rework), and validated a depth-sensor failure-recovery sequence that would be risky to test on real hardware.
On top of the simulation, proposed and designed 4 software-level upgrades over a reference system: UDP/H.264 video streaming, Kalman filter sensor fusion, YOLOv8-nano onboard object detection, and active thermal management.
Research published as conference paper. Hardware integration phase upcoming.
Stack: Python · MATLAB · PID Control · Kalman Filter · YOLOv8 · Embedded Systems · Raspberry Pi (planned)
Skills -
Embedded Systems Python IoT AI/ML Robotics Control Systems1 like · 3 views · Oct 19, 2026
Developed a digital twin for ROV, simulating physics, control, and sensor behavior in Python.

