
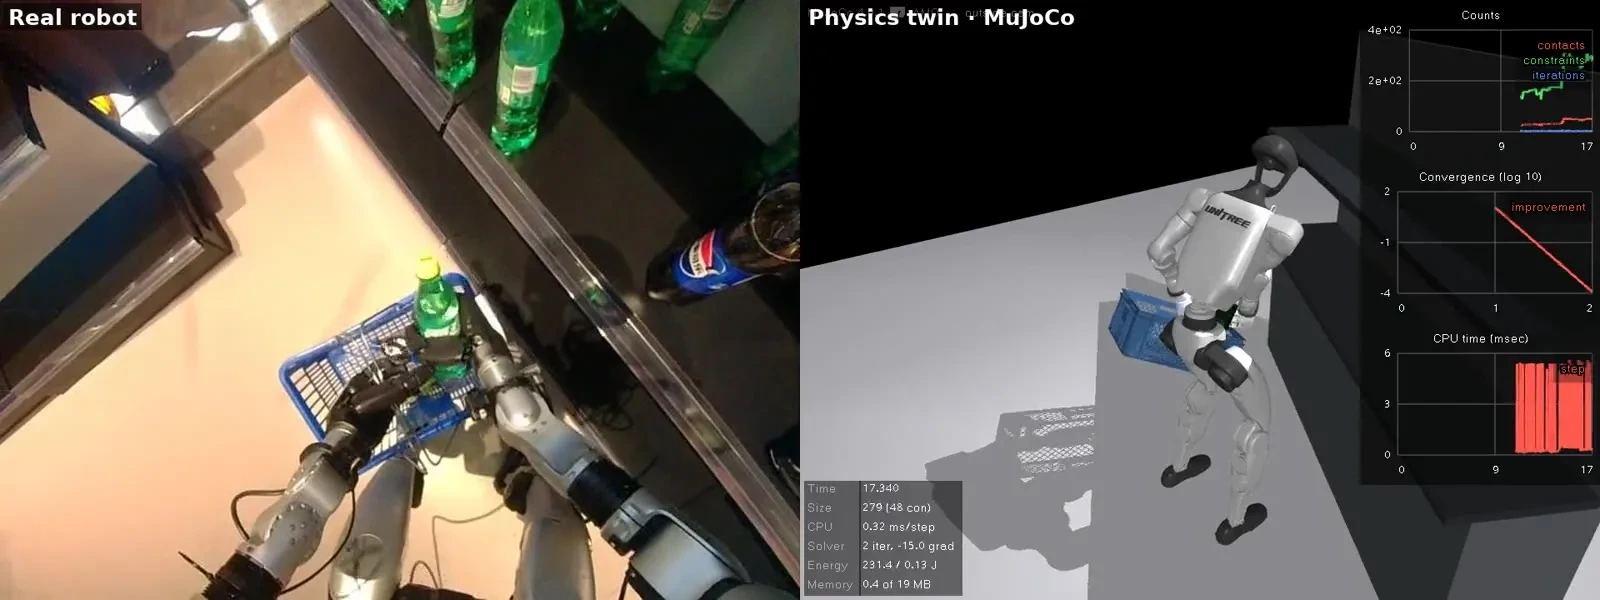
Same pipeline, another job: drinks from a shelf into a basket.
A Unitree G1 picks two bottles from a shelf and puts them into the basket its left hand carries. We rebuilt the scene to scale and reran the recording in physics: both bottles are picked by friction and placed in the basket; the robot balances on its own controller.
What was checked on the run
No fall.
Both bottles grasped by friction and released into the basket.
Every object collides with every other.
Disclosed: the basket stays attached to the left hand for the whole clip, as in the real recording where that hand holds the handle throughout.
Physics twin in MuJoCo 4.0.1 with its own telemetry. Real footage: Unitree Robotics open dataset (Apache-2.0).
This is how FOI works for a venue: we rebuild your space as a physics twin, teach the robot your job there, and only ship a skill that passes your checks. More: market.forenly.ai
0 likes · 0 views · Nov 18, 2026
A real Unitree G1 recording of picking two bottles from a shelf into a basket, rerun as a physics twin in MuJoCo 4.0.1: both bottles picked by friction, the robot balancing on its own controller.
Timeline
Nov 16, 2026 - Nov 16, 2026
