
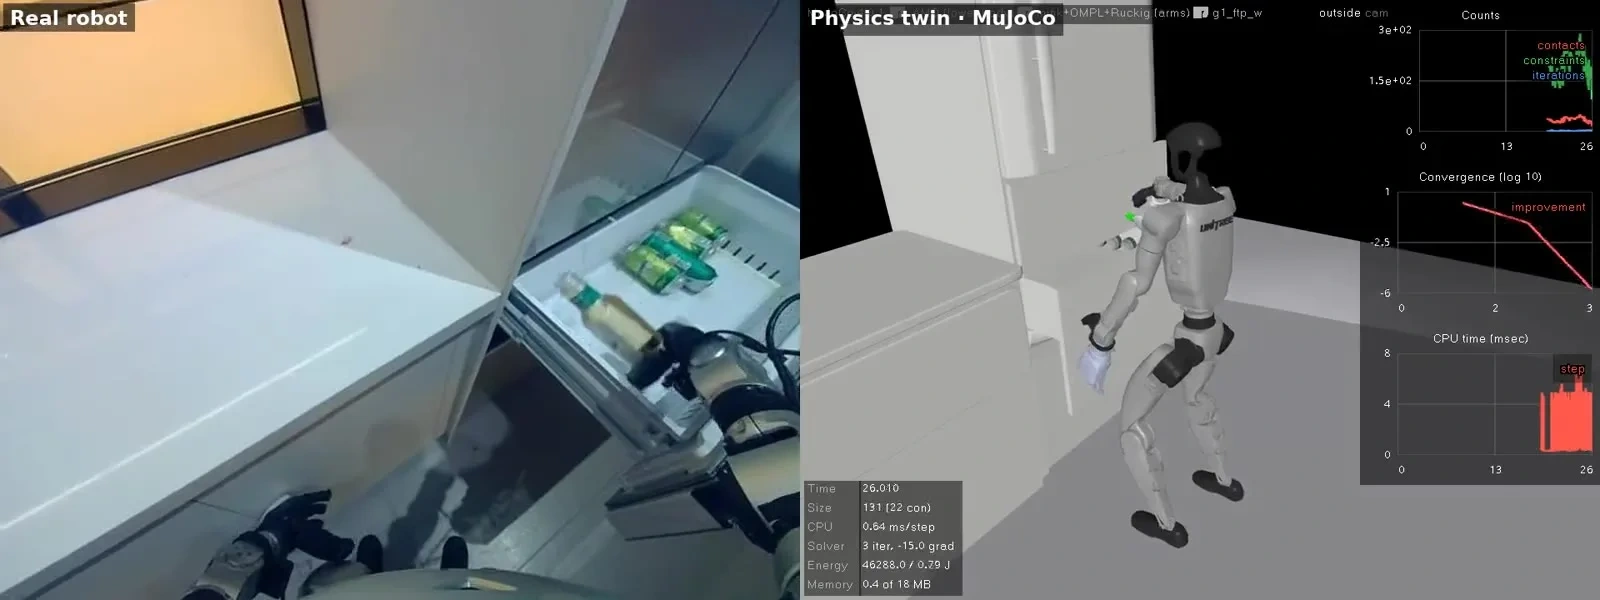
A real robot's job, rebuilt and rerun in physics.
Left: a Unitree G1 putting a drink into a fridge drawer, recorded on a real robot. Right: the same job in its physics twin. The robot balances on its own, picks the bottle up by friction, hands it over, puts it in the drawer and closes it. Nothing is glued to the hand; every object collides with every other.
How it works
Real recording: joint angles, hands and head camera of a real robot doing the job.
Digital twin: counter, fridge drawer, bottle and cans rebuilt to scale from open asset libraries.
Physics rerun: balance by the robot's own controller, arms planned around obstacles, grasp by friction.
Measured: grasp, hand-over, release and drawer closing checked on every run.
Physics twin in MuJoCo 4.0.1 with its own telemetry: time, contacts, solver iterations, energy and CPU time per step. Real footage: Unitree Robotics open dataset (Apache-2.0).
This is how FOI works for a venue: we rebuild your counters, fridges and rooms as a physics twin, teach the robot your job there, and only ship a skill that passes your checks. More: market.forenly.ai
0 likes · 0 views · Nov 18, 2026
A real Unitree G1 recording of putting a drink into a fridge drawer, rebuilt and rerun as a physics twin in MuJoCo 4.0.1: balance by the robot's own controller, grasp by friction, nothing glued to the hand.
Timeline
Nov 16, 2026 - Nov 16, 2026
