Three-camera color match pipeline

Vincent L. Anderson


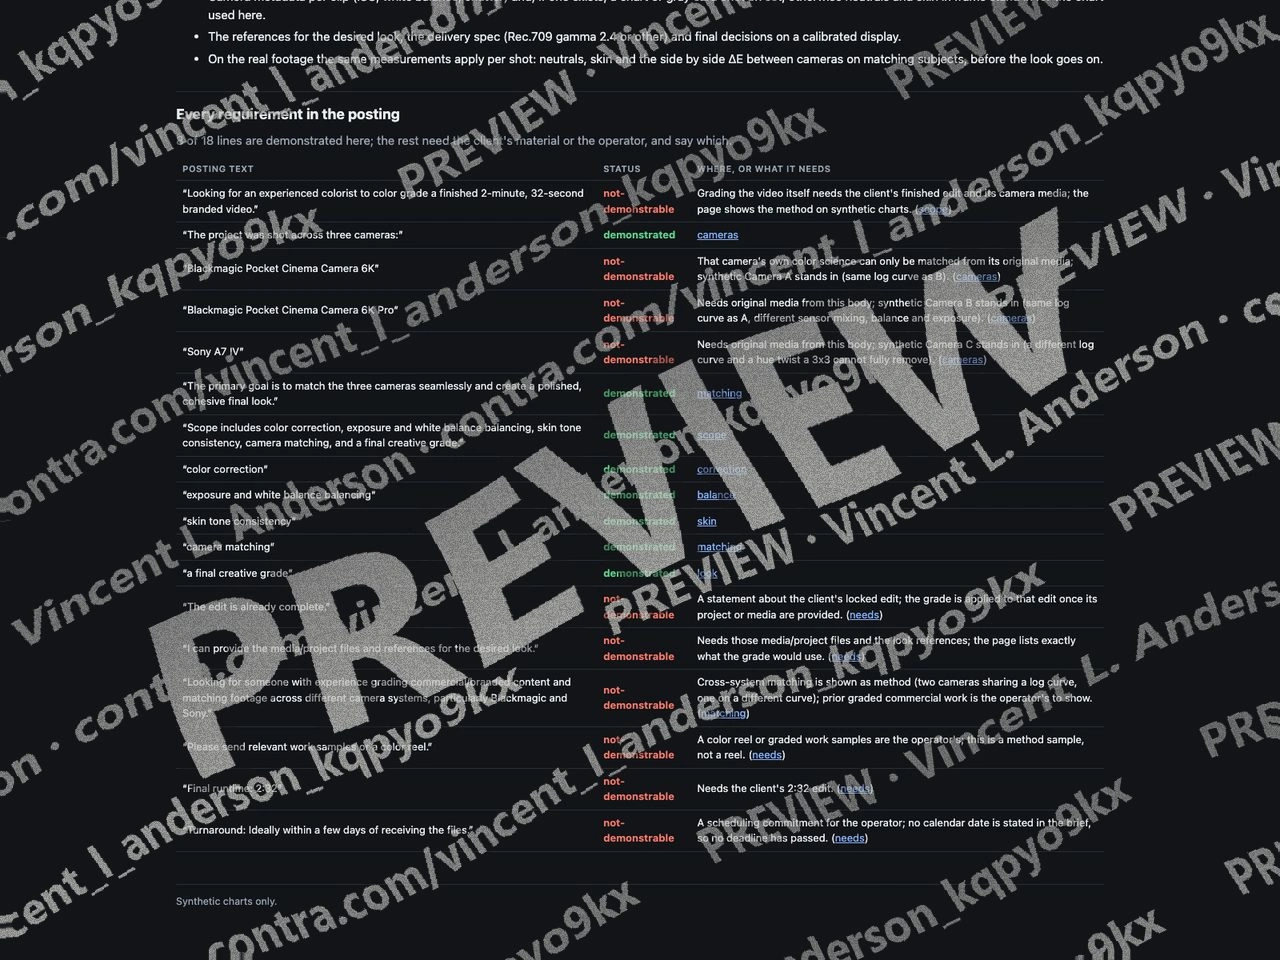
A demo built for a specific brief. Not client work: the material shown is sample data, so what is on display is the mechanism.
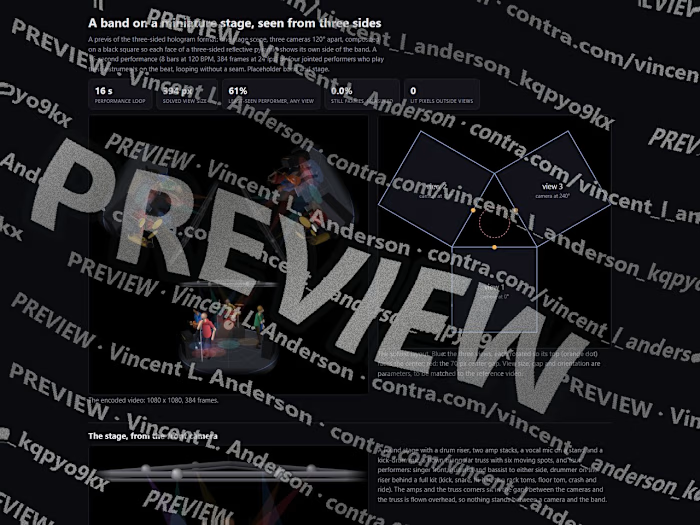
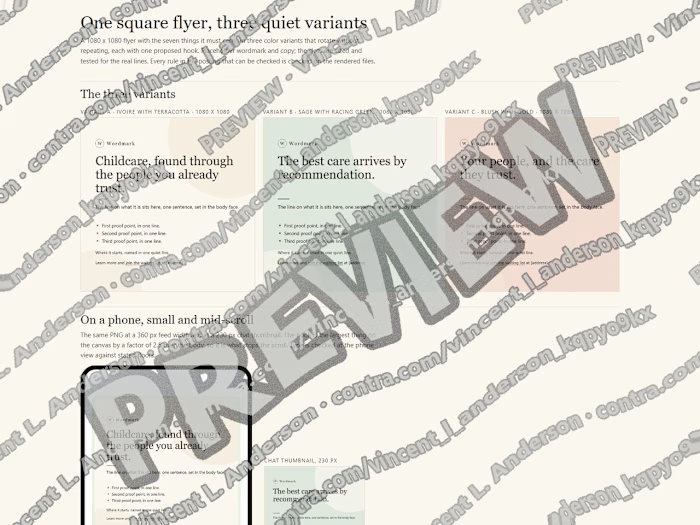
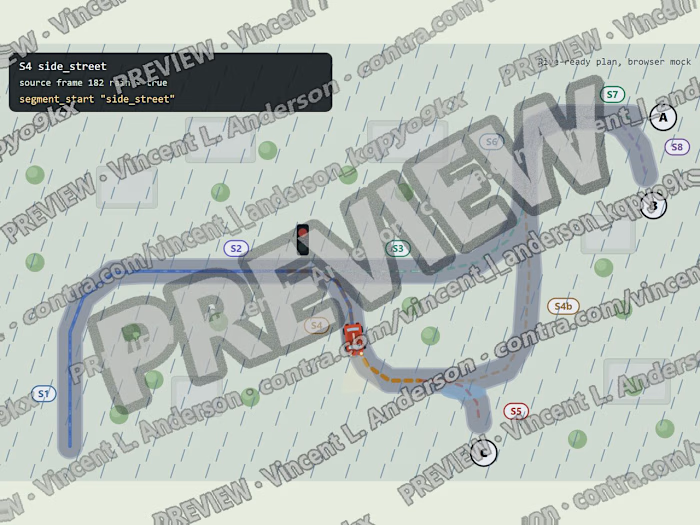
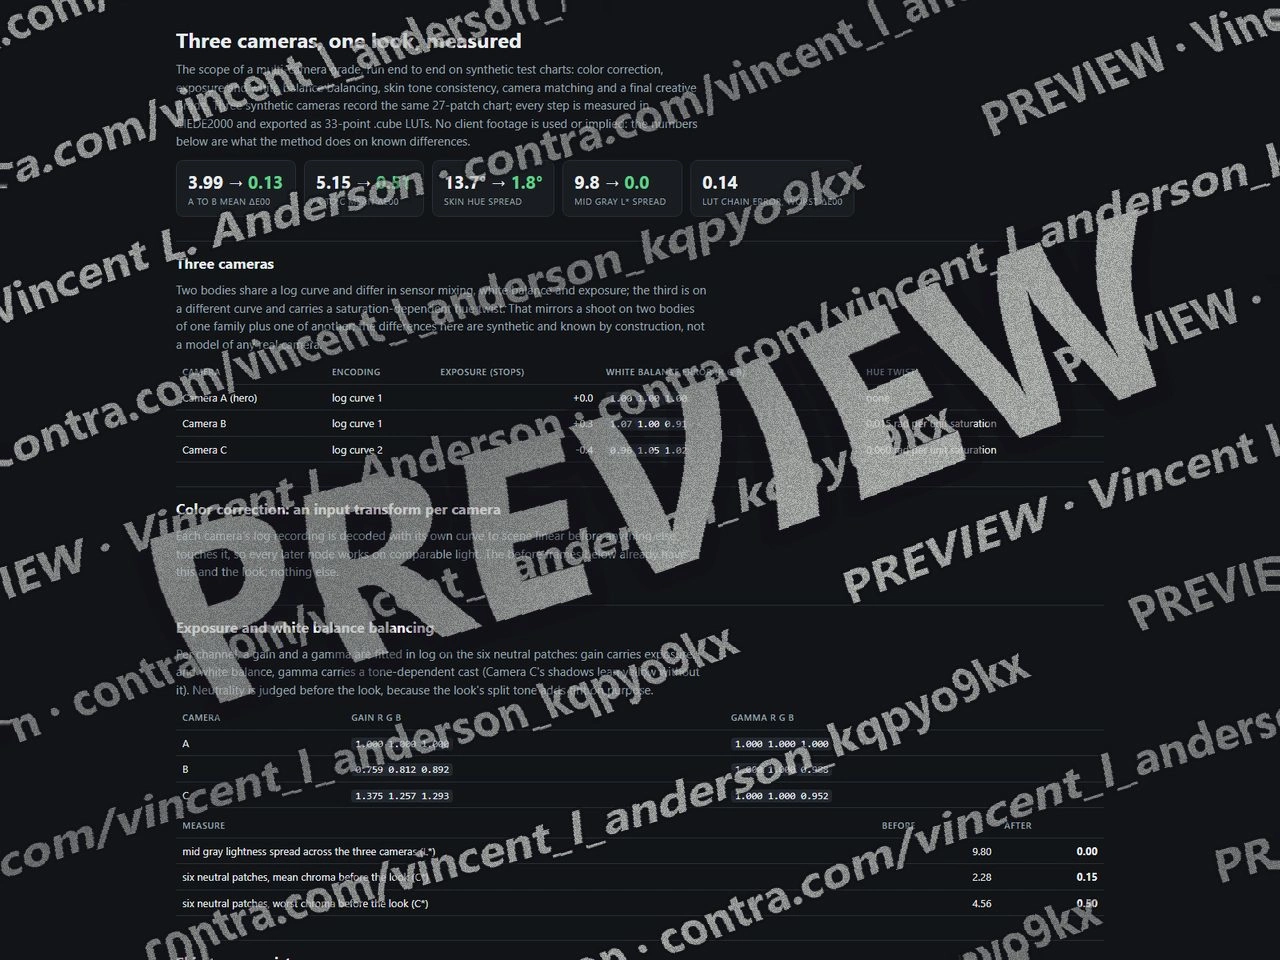
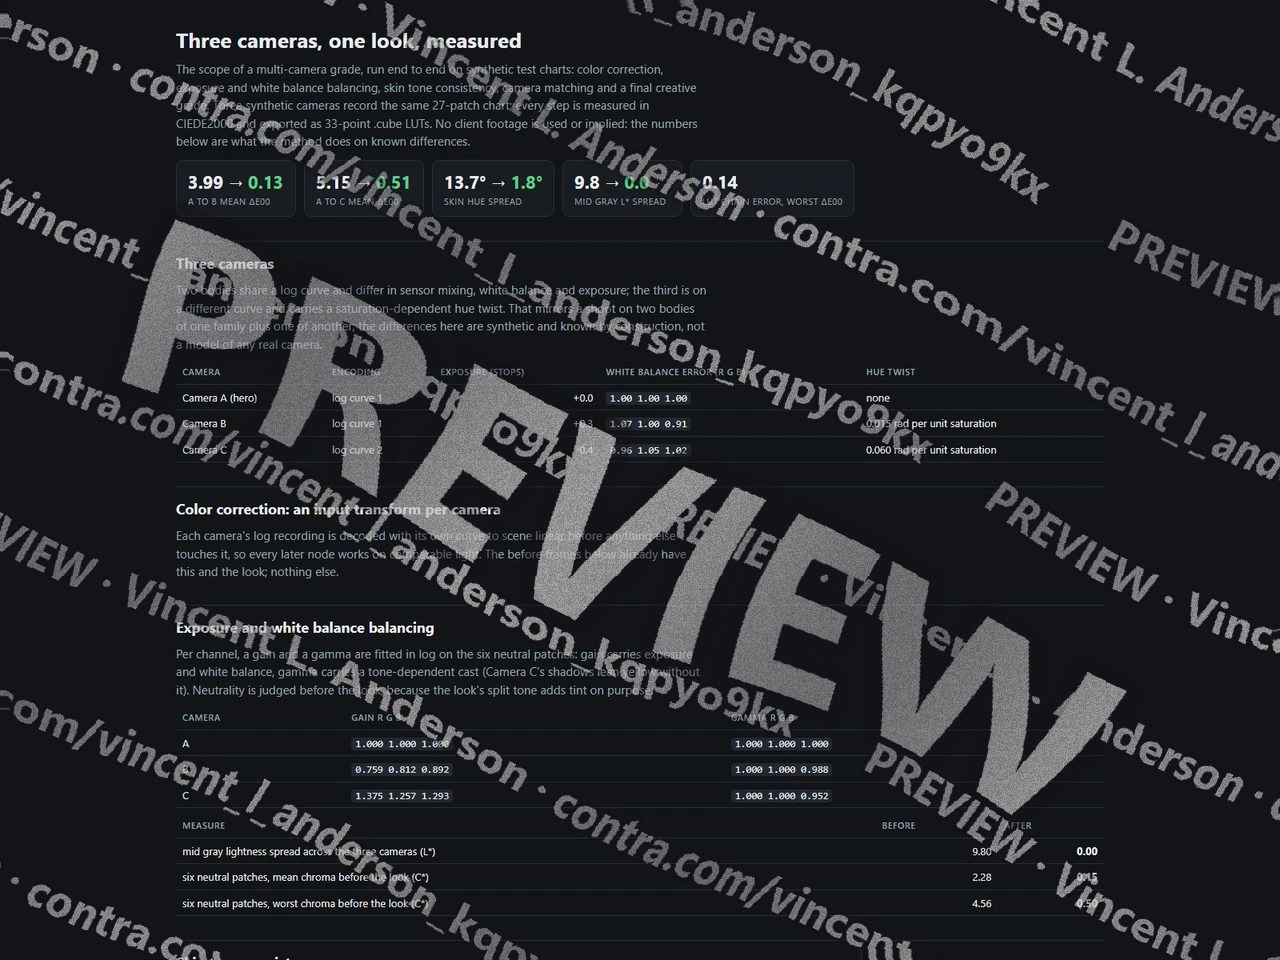
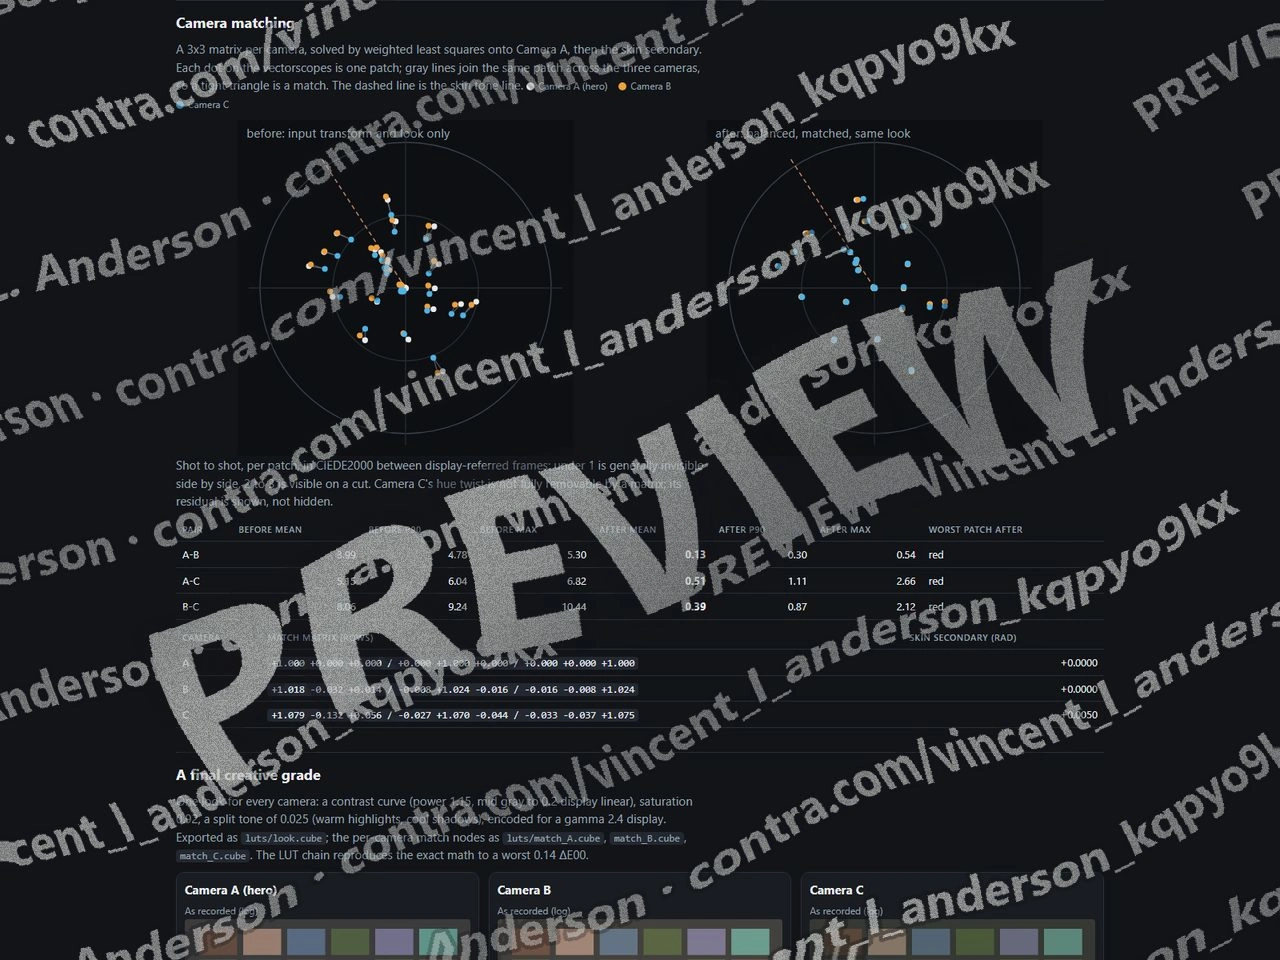
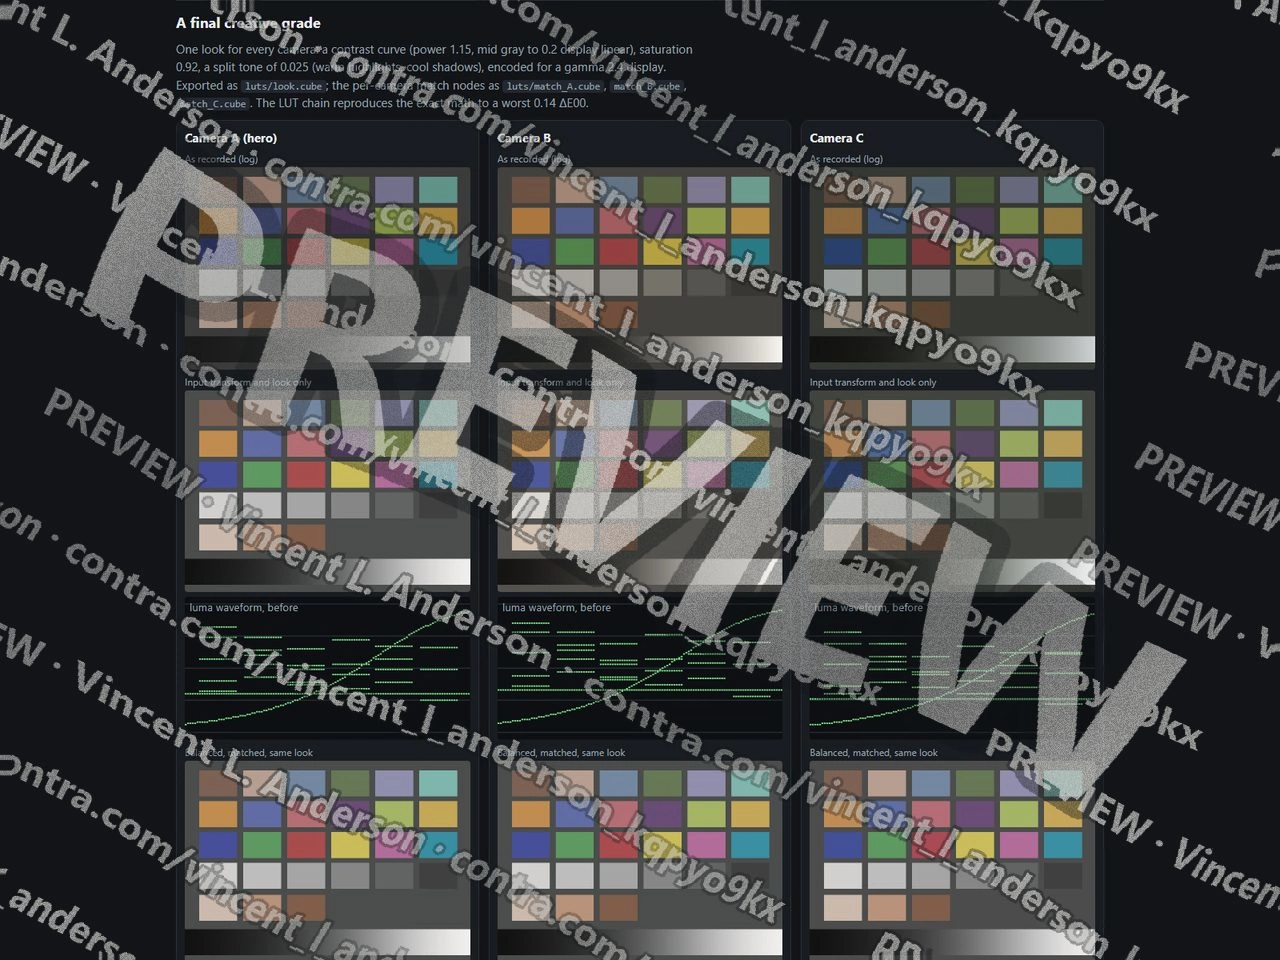
I built a deterministic three-camera match and ran it on synthetic charts, not client footage. Three synthetic cameras record the same 27-patch chart (24 checker patches plus 3 skin patches); two share a log curve, the third uses another and carries a hue twist. Per camera the build decodes the log curve, fits a per-channel gain and gamma on the six neutrals, solves a 3×3 match onto the hero camera (skin weighted 4x) plus a qualified skin secondary, then applies one look to all. Mean CIEDE2000 A to B falls from 3.99 to 0.13 and A to C from 5.15 to 0.51 (p90 1.11); skin hue spread from 13.72° to 1.76°; mid gray L* spread from 9.80 to 0.00. Vectorscope, waveform and histogram are computed from the rendered frames, and the 33-point cube-format LUT chain reproduces the math to 0.14 ΔE00 worst. The build asserts these targets and writes nothing on failure.
Three-camera color match pipeline 1
Three-camera color match pipeline 2
Three-camera color match pipeline 3
Three-camera color match pipeline 4
Like this project
Posted Sep 23, 2026
I built a deterministic three-camera match and ran it on synthetic charts, not client footage.
Likes
0
Views
0