Intelligent UAV Development with Autonomous Capabilities

Asad Mahmood Asghar


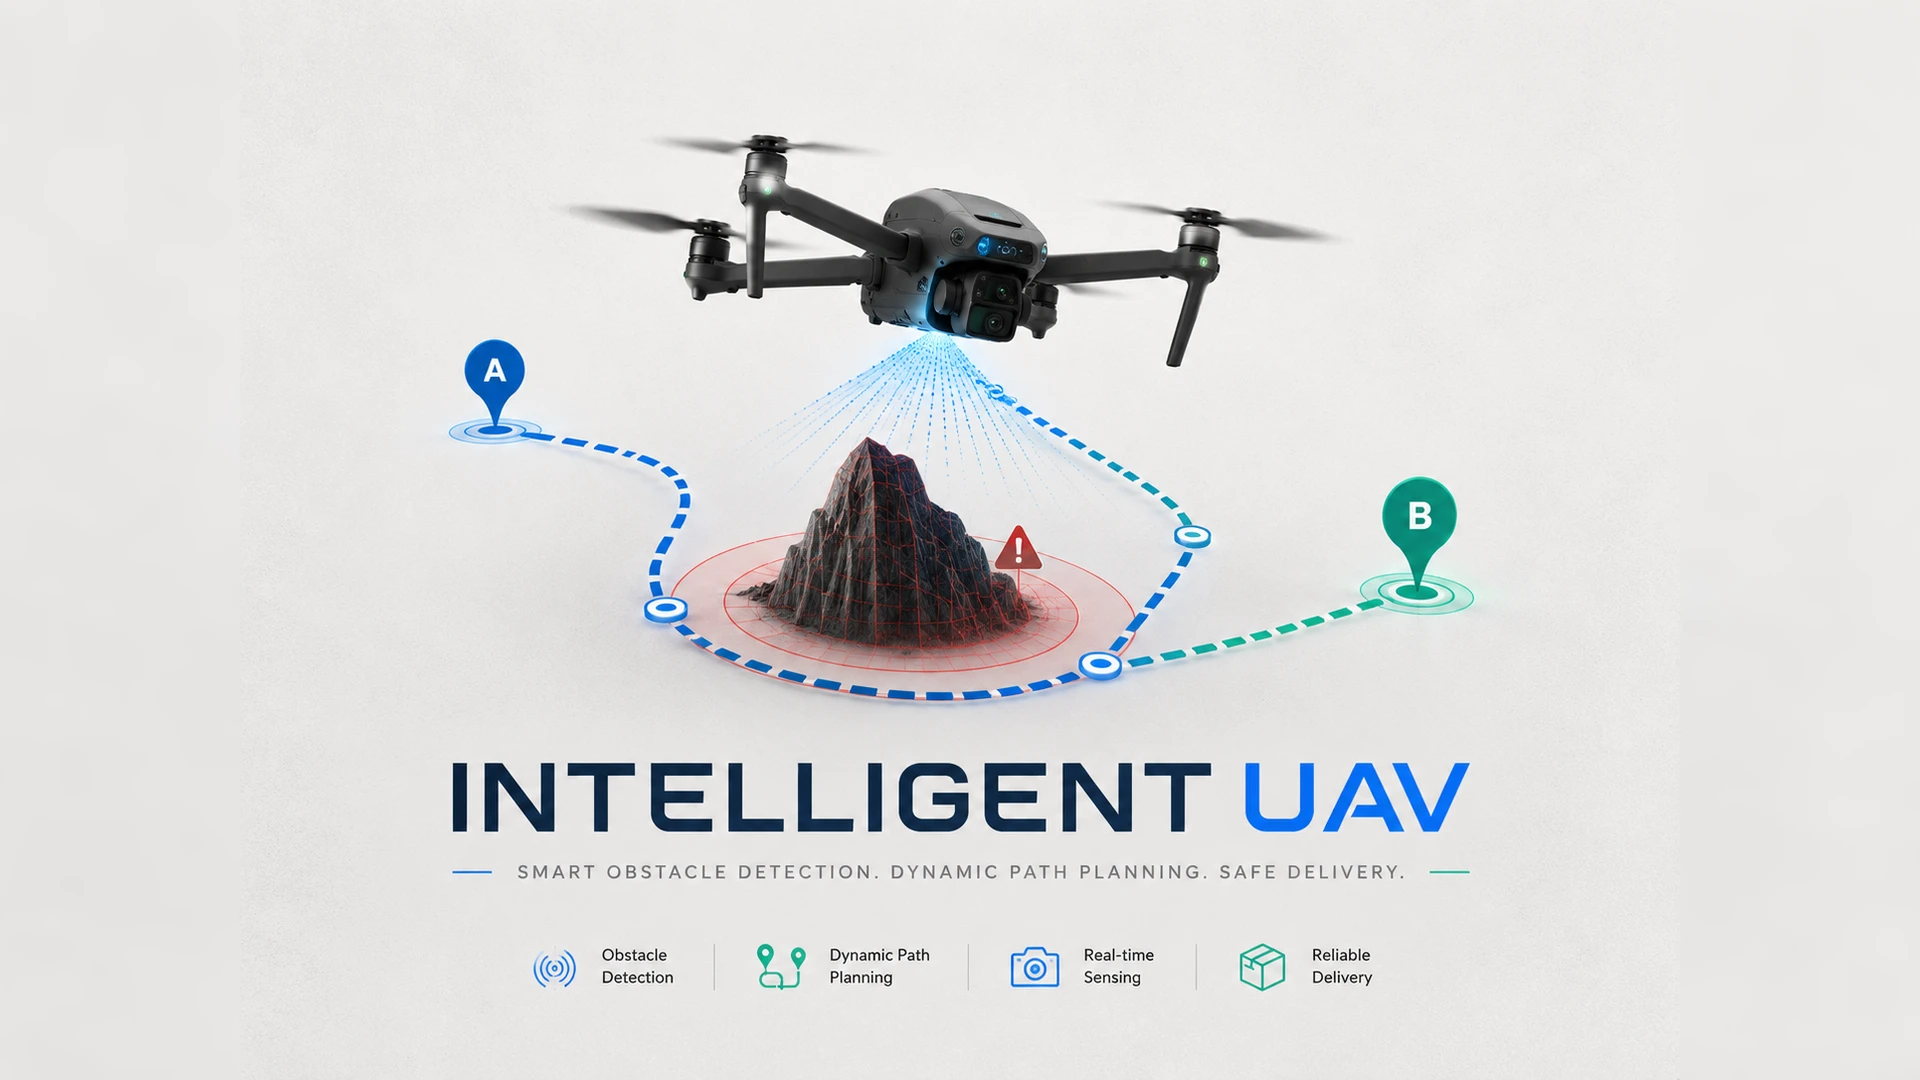
Built an intelligent Unmanned Aerial Vehicle (UAV) capable of autonomous flight, target detection, and decision-making using advanced sensor systems. The system featured real-time obstacle avoidance and automatic execution of pre-defined missions through an array of LiDAR and IR sensors for precise range detection. Using a Raspberry Pi as the main processing unit connected to a Pixhawk flight controller via DroneKit, the system could dynamically navigate and avoid obstacles. The project focused on multi-threaded processing on the Raspberry Pi, PID tuning for stable flight, and integration of LiDAR, IR sensors, and GPS/IMU modules for comprehensive spatial awareness. The UAV demonstrated reliable performance in various environments with its sensor-based obstacle detection capabilities.
Key Contributions:
• Implemented autonomous navigation and obstacle avoidance algorithms.
• Tuned PID controllers for flight stability and responsiveness.
• Integrated sensor data (LiDAR, IR sensors, GPS, IMU) for real-time control.
• Deployed and tested the system using ROS and Ardupilot simulation.
Tech Stack:
Python, Javascript, GPS, C++, Raspberry Pi, ROS, html canvas, PID, Ardupilot, lidar, IR sensors, pixhawk flight, drone kit
Like this project
Posted Jul 31, 2025
Developed an intelligent UAV with autonomous flight and obstacle avoidance.
Likes
0
Views
0