
I built and studied a multi-robot coordination system in Webots to understand how different navigation strategies affect team performance in exploration tasks. Using Clearpath PR2 robots, I implemented and compared Route, Survey, and Mixed human-inspired strategies, along with obstacle avoidance and conflict resolution in C++. By running controlled simulations, I measured how strategy choice impacts task completion time, coverage, and coordination efficiency. One key result was that mixed strategies consistently produced more robust and efficient teams, offering insights directly relevant to real-world search, rescue, and exploration robotics.
11
175
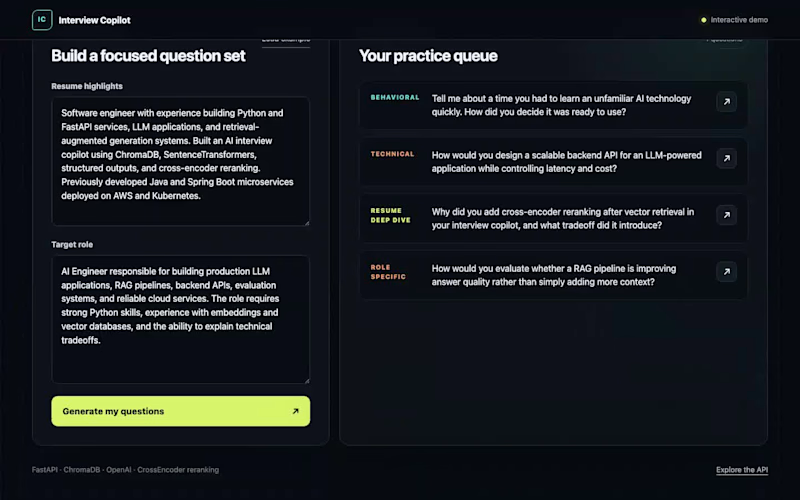
AI Interview Copilot is a RAG-powered interview assistant that retrieves relevant information from a personalized knowledge base and uses an LLM to generate context-aware responses to interview questions. I built the retrieval and generation pipeline to combine semantic search with prompt-based reasoning, allowing responses to stay grounded in relevant source content rather than relying only on the model’s general knowledge.
0
43

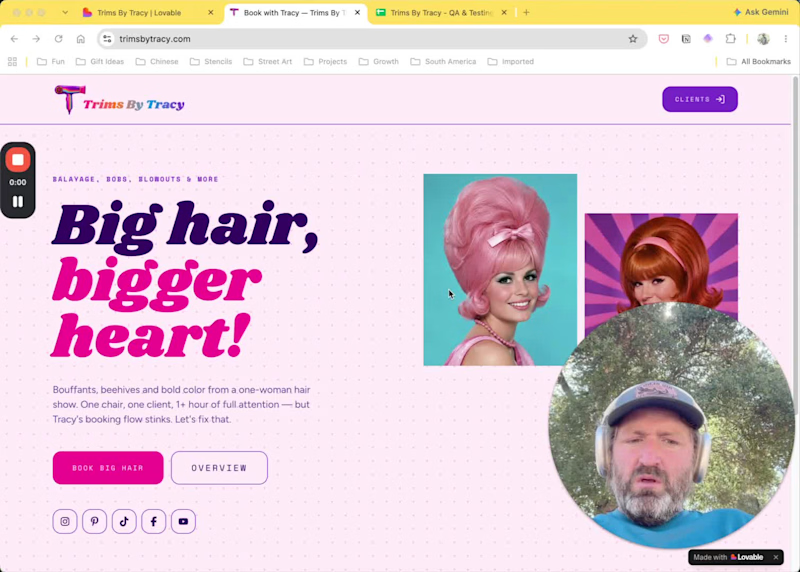
Know someone who needs a haircut? 🙋
Send them to TrimsByTracy.com (http://TrimsByTracy.com?ref=drake), where they will find the salon of Tracy Turnblad (https://hairspray.fandom.com/wiki/Tracy_Turnblad), a solo hairstylist in Baltimore who needed an expert to tame her booking flow the way she tames manes.
I had a lot of fun working on this Proof of Concept, from ideating design system inspiration to working through the nooks and crannies of a hairstylist's booking flow, to figuring out how to succinctly communicate the value added in an overview video.
I also continue to learn each time I build something new with Lovable. This time I was focused on reducing the amount of time spent testing, which is what my "Process" video is about. I hope you'll take a look at that since I personally think what I shared there is very valuable and should be standard to all builders' workflow and possibly considered for productization by Lovable.
Regardless, I hope you enjoy taking a look around TrimsByTracy! All built with care in Lovable.
- Drake
https://trimsbytracy.com/
(https://trimsbytracy.com/?ref=drake)https://trims-by-tracy.lovable.app (https://trims-by-tracy.lovable.app?ref=drake)
7
3
410





Multi-Robot Coordination & Simulation in ROS2
Designed and implemented a ROS2-based multi-robot simulation platform to study coordination, navigation strategies, and communication-aware exploration.
Integrated SLAM Toolbox, Nav2, map merging, and multi-agent coordination logic. Used Python and C++ nodes with live visualization in RViz to evaluate efficiency, coverage, and cooperation under different strategies.🚀
21
304