The network for creativity
Join 1.25M professional creatives like you
Connect with clients, get discovered, and run your business 100% commission-free
Creatives on Contra have earned over $150M and we are just getting started
Back to feedPost

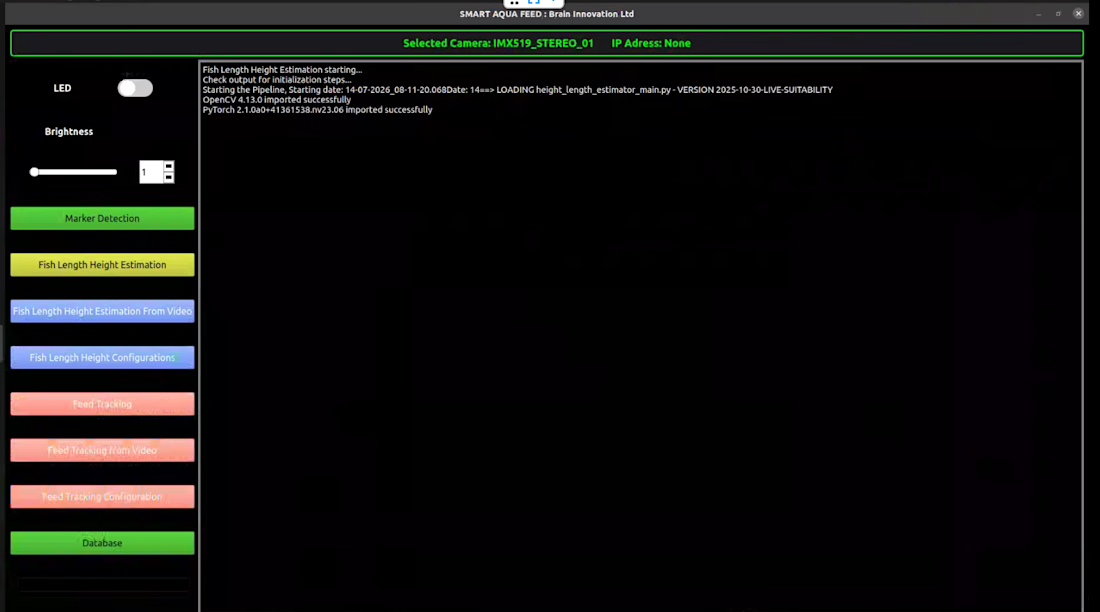
Built a real-time fish measurement and feed tracking system for aquaculture, deployed on NVIDIA Jetson AGX Orin with OAK-D stereo cameras. Worked remotely with the client on stereo camera calibration, depth-based fish length/height estimation, and parallel feed pellet tracking, plus a custom PyQt5 app for live monitoring and control. Solved key challenges in real-time performance, GPU memory optimization, and camera calibration on constrained edge hardware all through remote hardware collaboration.


The network for creativity
Join 1.25M professional creatives like you
Connect with clients, get discovered, and run your business 100% commission-free
Creatives on Contra have earned over $150M and we are just getting started





Related posts

I've never made an ad like this and I'm really proud of it! It's for Cosign, an app I designed that helps users understand and manage terms and agentic permissions.
Digital consent, basically.
Every frame rendered in Blender on my M1 Max, which took a while.
Figma x Opus 5.5 x Blender


built a pond you can't fall into.
real wave sim in WebGL, sunlight through blinds that wobbles with every ripple, maple leaves that fold, float, get pushed around and eventually sink.
Link - https://water-repel.vercel.app


I built an interactive 3D library experience that turns browsing books into something more immersive.
From animated 3D elements and parallax movement to interactive books and smooth transitions, the goal was to make the website feel less like a page and more like a digital space you can explore.
Built with creativity, interaction, and storytelling at the center.
