The network for creativity
Join 1.25M professional creatives like you
Connect with clients, get discovered, and run your business 100% commission-free
Creatives on Contra have earned over $150M and we are just getting started
Back to feedPost

Tilt-Compensated Digital Compass with IMU-Magnetometer Fusion
Architected and engineered a high-reliability embedded sensor fusion framework to build a navigation-grade tilt-compensated digital compass. Utilizing a 3-axis magnetometer coupled with a 3-axis accelerometer (IMU), this system accurately estimates true heading dynamically, overcoming physical tilt errors and local magnetic field distortions in real-time.


The network for creativity
Join 1.25M professional creatives like you
Connect with clients, get discovered, and run your business 100% commission-free
Creatives on Contra have earned over $150M and we are just getting started



Related posts

Two 3D motion ads built from real 3D models: a Bauhaus shape playground and a delivery city with a driving van. One camera, two moods.
2 voted
29%
5 voted
71%
7 votes
Closed


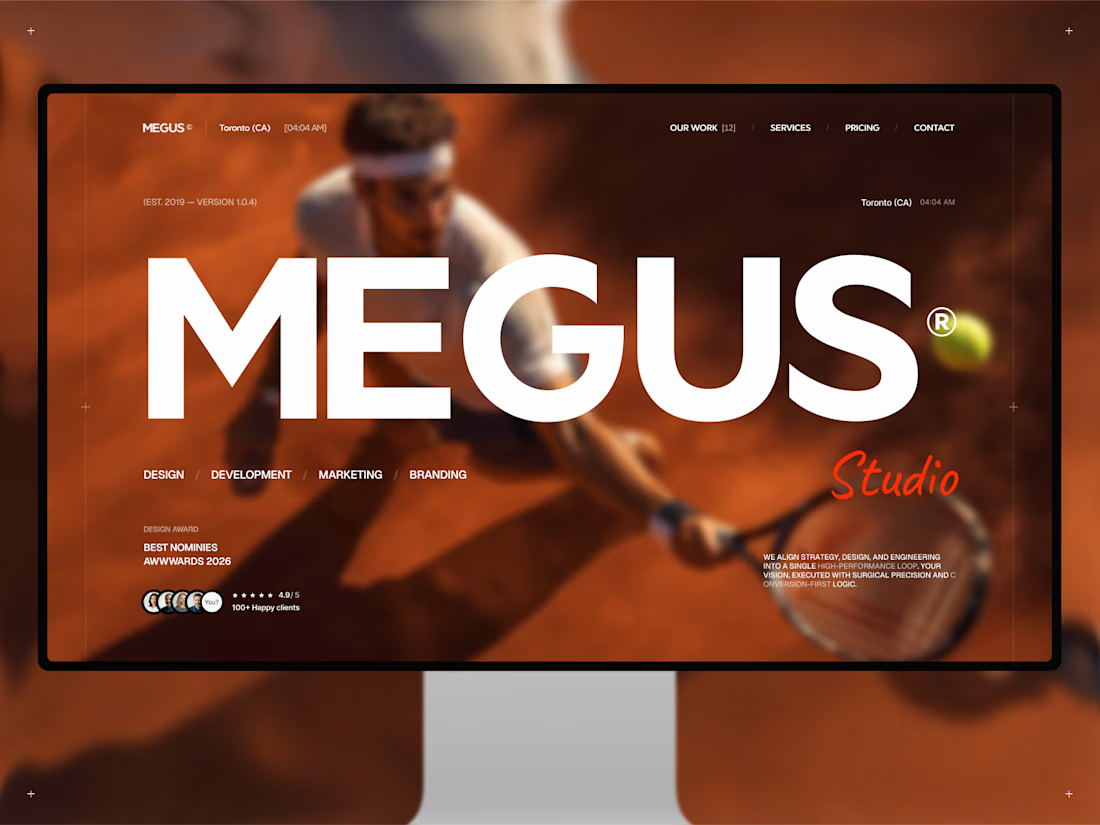
Finally, MEGUS® ⚡️ is live on the @Framer Marketplace! 🚀
After 2 months of focused work, the template is now published and ready.
MEGUS is a complete system for modern brand and portfolio sites — strategy, identity, motion, and development in one cohesive setup. 👾
Explore the full template and see it in action here:
https://www.framer.com/marketplace/templates/megus/
Available now. ⚡️



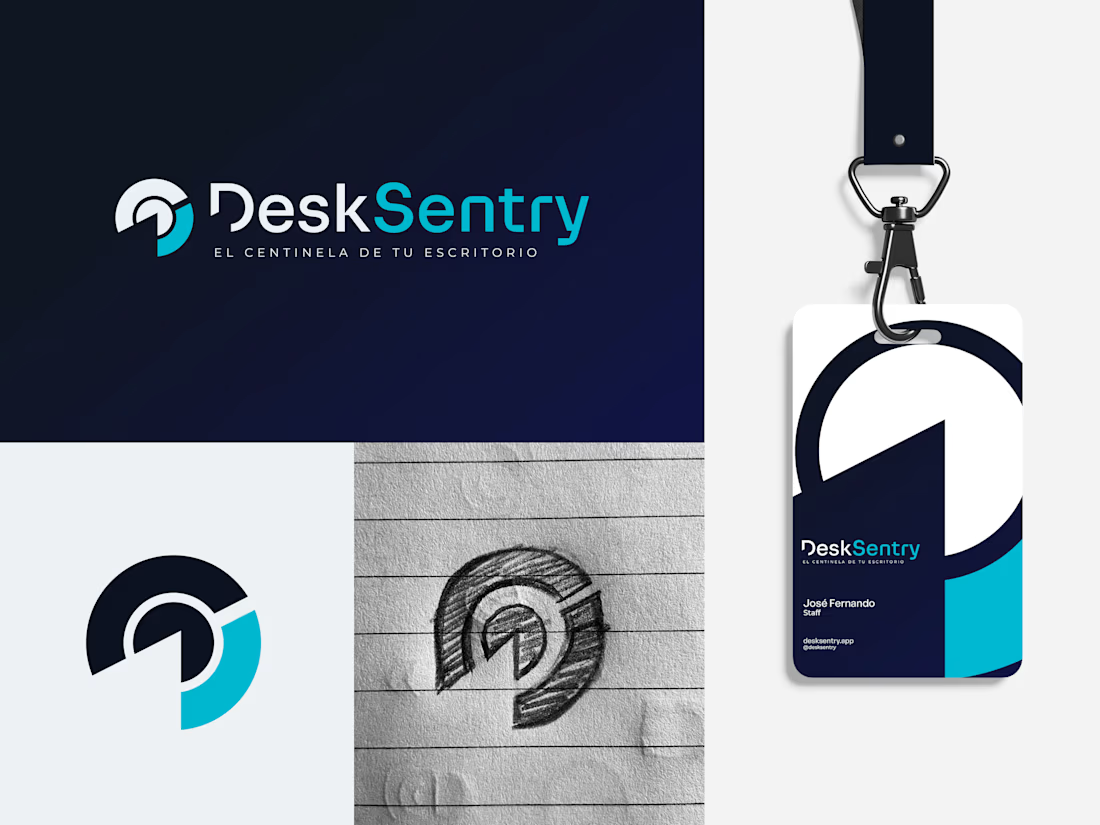
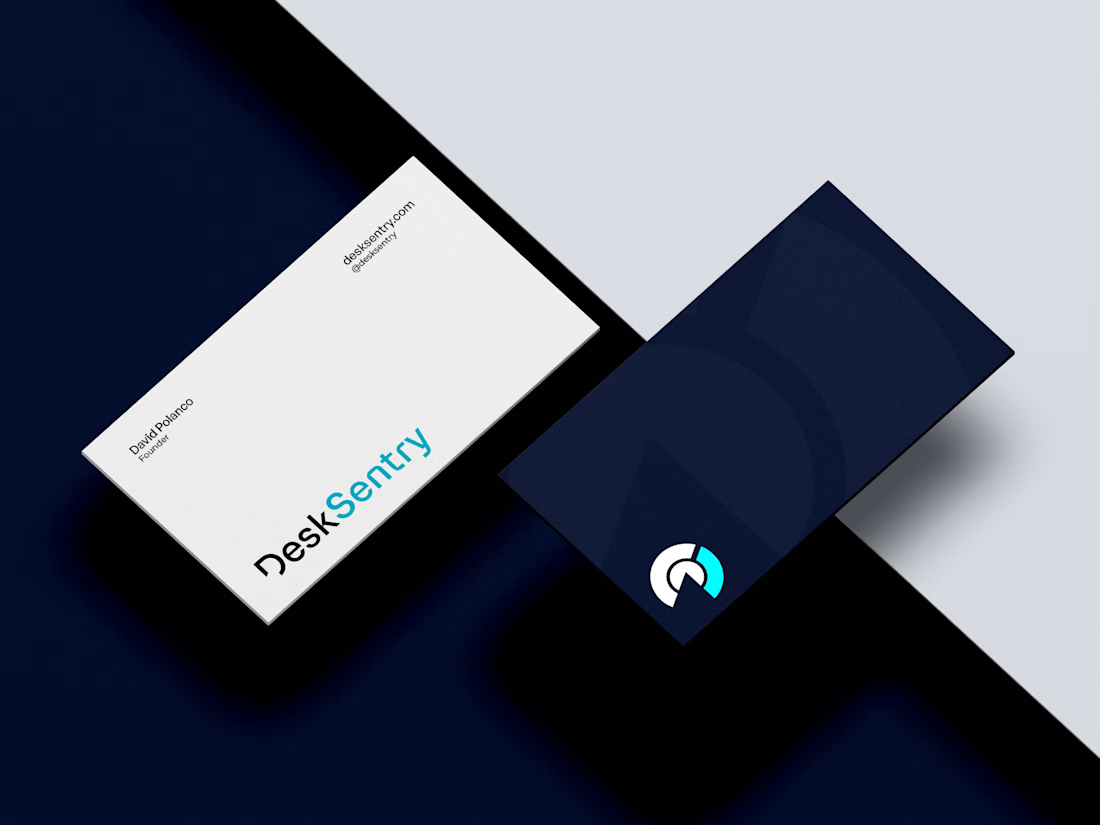
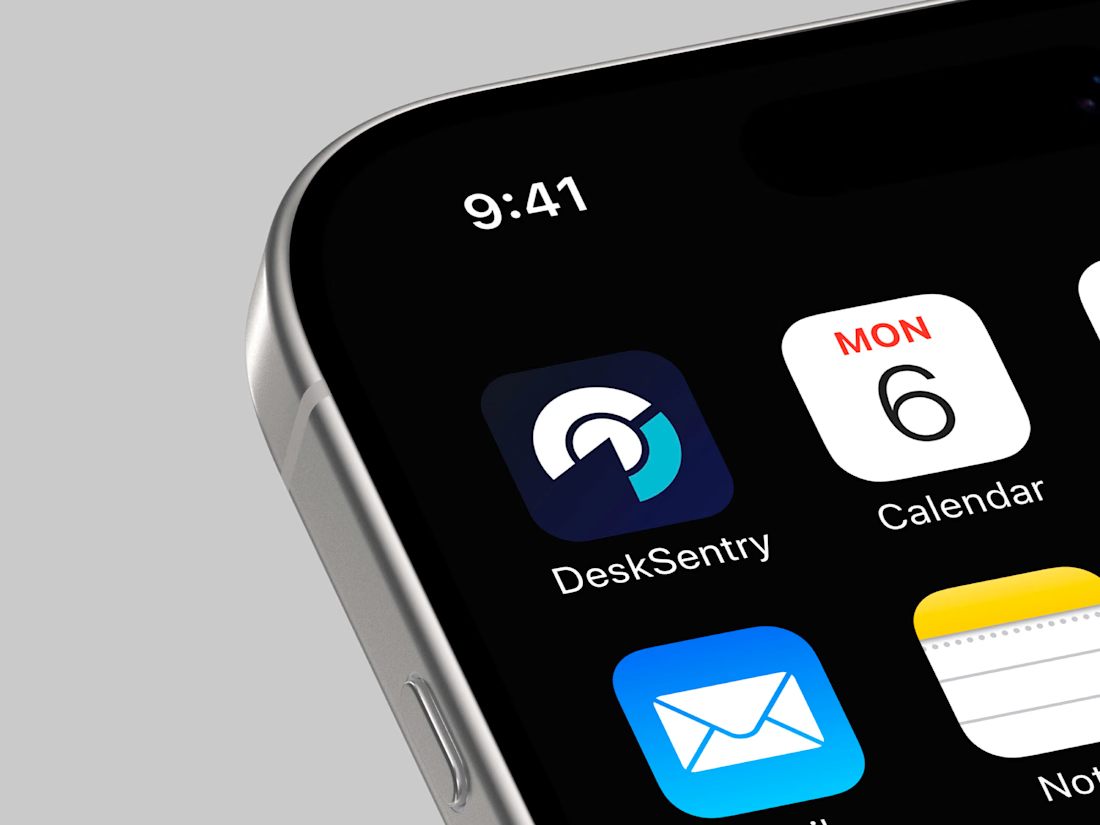
Meet DeskSentry.
A productivity app that quietly watches over your workday. So the brand needed to feel professional, trustworthy, tech-forward, but not intimidating or surveillance-heavy.

Great work