The network for creativity
Join 1.25M professional creatives like you
Connect with clients, get discovered, and run your business 100% commission-free
Creatives on Contra have earned over $150M and we are just getting started
Back to feedPost

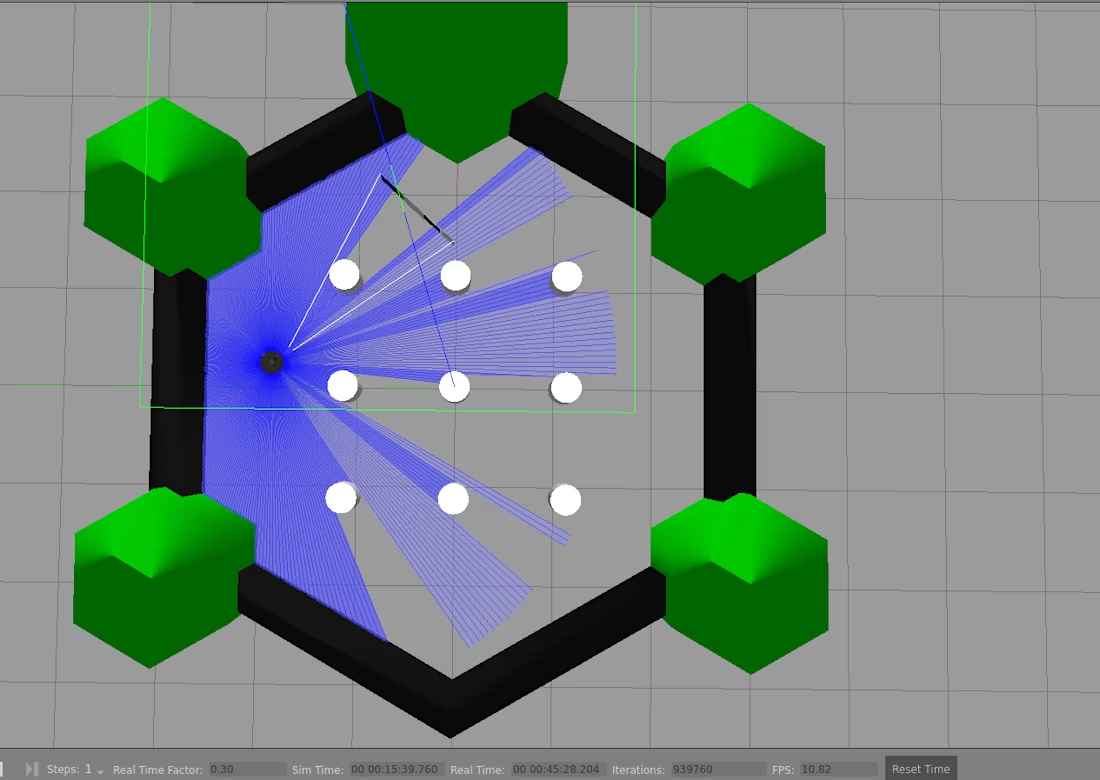
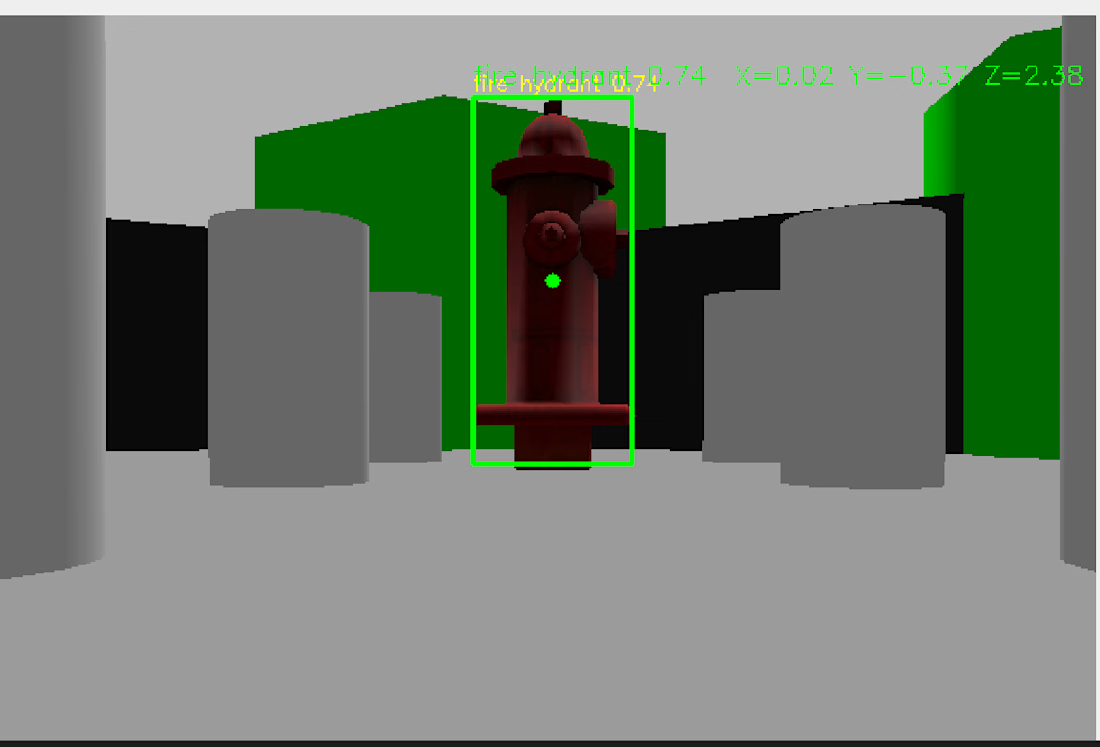
Autonomous Vision-Language Navigation Rover
Overview
Developed a simulated autonomous rover combining robotics, computer vision, and sensor-fusion concepts to explore navigation in a simulated environment.
Project focus
ROS 2 and Gazebo simulation.
Camera-based object perception using an ONNX model.
Integration of robotics sensors and localization concepts.
Exploration of vision-language navigation workflows.
Technologies: ROS 2 Humble, Gazebo, Python, ONNX Runtime, computer vision, sensor fusion.


The network for creativity
Join 1.25M professional creatives like you
Connect with clients, get discovered, and run your business 100% commission-free
Creatives on Contra have earned over $150M and we are just getting started





Related posts

HandOff ™ | 3d Robotics Animation

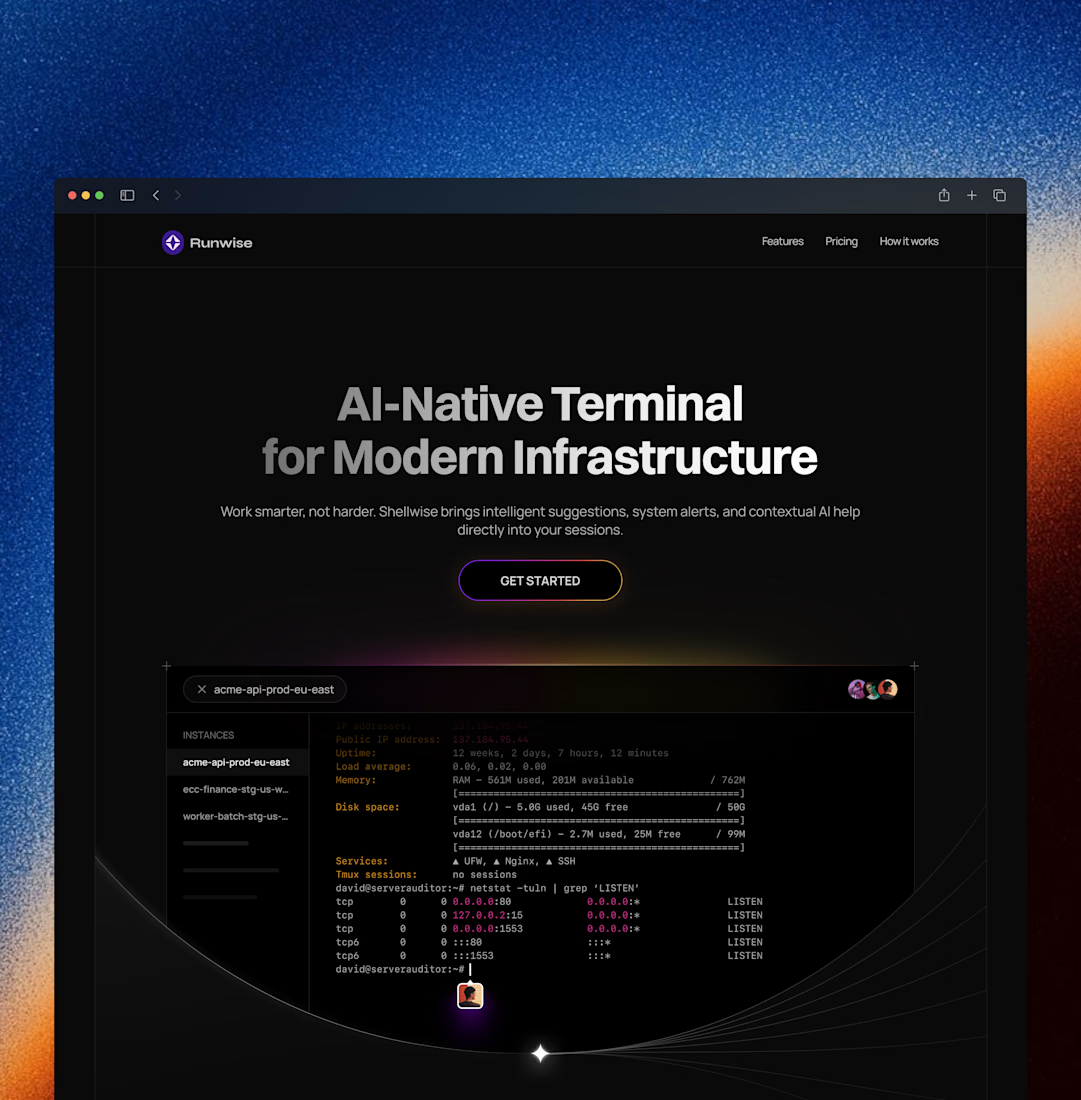
Landing page for an AI-native terminal platform




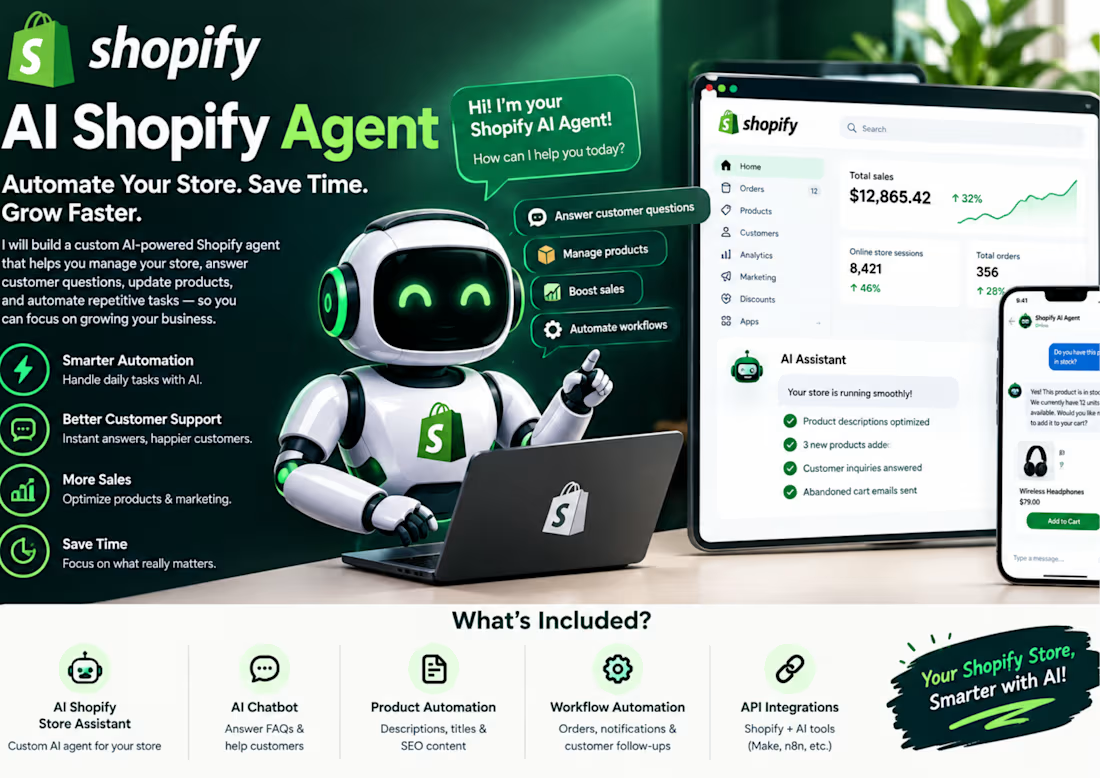
Develop and configure an AI-powered assistant for a Shopify store to help customers find product information, answer frequently asked questions, and improve the shopping experience. The project includes discussing requirements, configuring compatible AI tools, testing chatbot responses, and providing the agreed setup. Any paid third-party apps or API fees are excluded unless agreed in writing. Final features and delivery dates will be confirmed with the client.


I'd use live Shopify data for price and stock, and reserve the indexed content for product descriptions and FAQs. How are you planning to test a variant whose price changes between the customer's first question and a follow-up in the same chat?