
Architectural Technologist | Luxury Design Specialist
View more →

Brands, websites & AI ads that get you found. EN + AR.
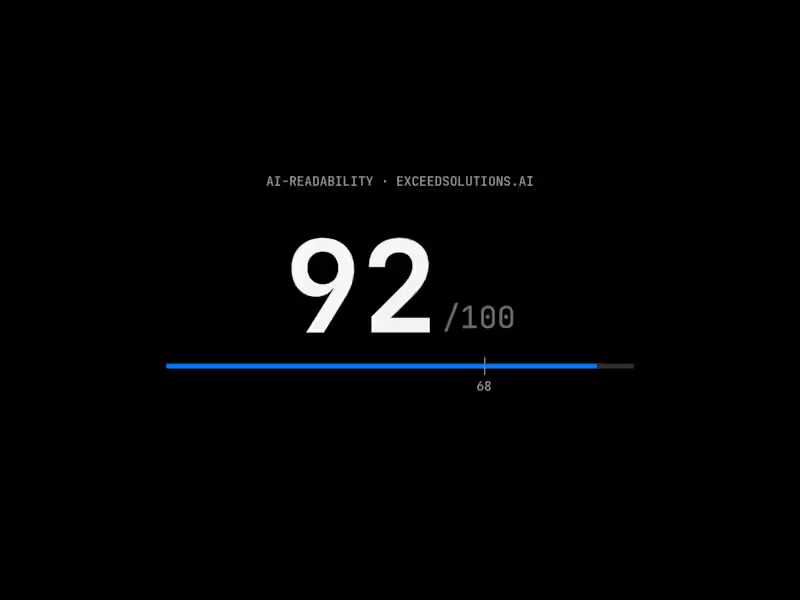
Websites AI recommends: the Exceed Solutions case film. Before people call a business, they ask an AI. I rebuilt exceedsolutions.ai (https://exceedsolutions.ai) so Google and AI assistants can read it and recommend it: bilingual Arabic/English pages, a sales path from a free check to a package in local currency to a PayPal deposit, and a system that runs on its own. AI-readability went from 68 to 92. Designed, built and run by Keith Al Mifrigi.
0
28
Abu Al-Ragheb Tires: from a logo to a whole brand. A 1963 family tire house with five branches in Amman came with a logo and no website. I built everything around it: a 25-page brand manual, storefront and interior signage, uniforms, van livery, stationery, motorsport banners, and a bilingual website with a WhatsApp tire finder. AI-readability went from 0 to 90. Brand, website and systems by Keith Al Mifrigi, Exceed Solutions.
2
0
72
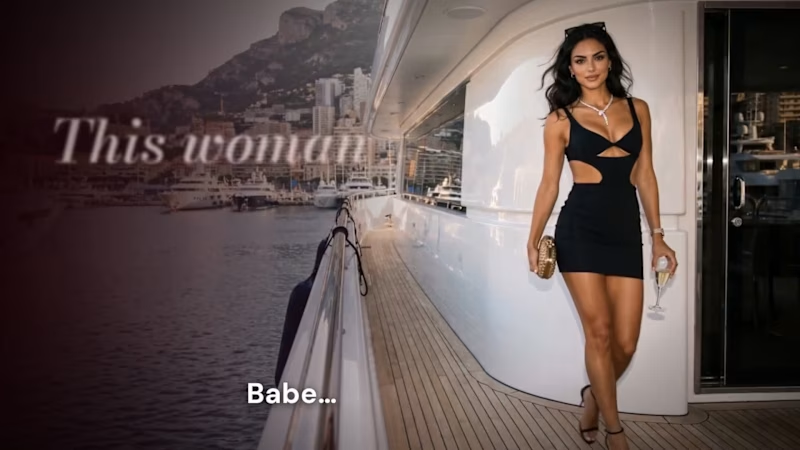
Lina Veyra: an AI commercial for an AI-made creator. I built Lina from scratch to 15.3K Instagram followers in 27 posts, then directed this 20-second commercial with her: script, every frame, English and Arabic captions, sound and edit. Not one frame was shot on a camera. The same process makes product ads and launch films for brands.
0
54
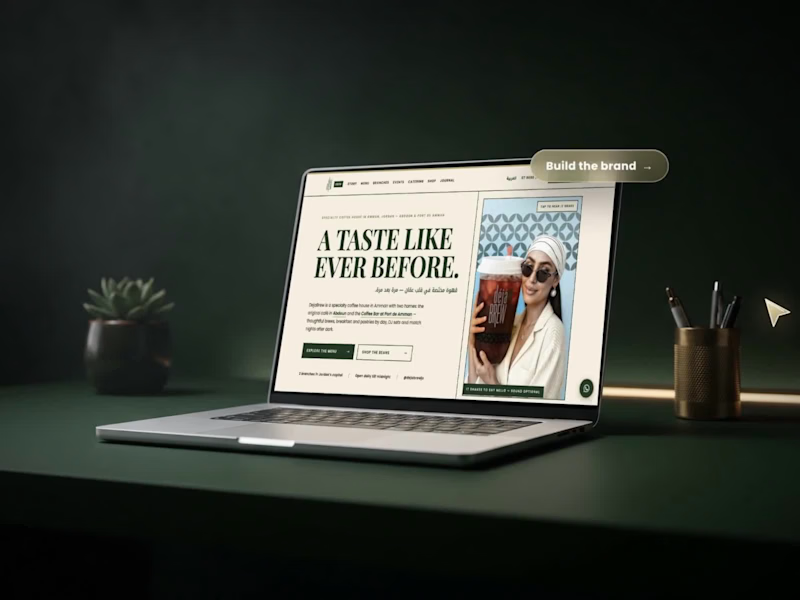
DejaBrew, Amman: the brand that runs itself. I built the 2026 brand system (palette lifted off the shop's own star tile, liquid-glass screen language, two-branch architecture), the bilingual website (AI-readability 74 to 90 in one day) and the automations that run it every week: content, Instagram replies, inbox, Google Maps, staff app and stats. Nobody presses a button.
0
56

For those Seeking Efficient, Authentic Brands.


Turning visions into reality, one creative stroke at a time.
Turning visions into reality, one creative stroke at a time.


View more →

Logo design
Logo design


View more →

Robotics Engineer | Embedded Systems Developer
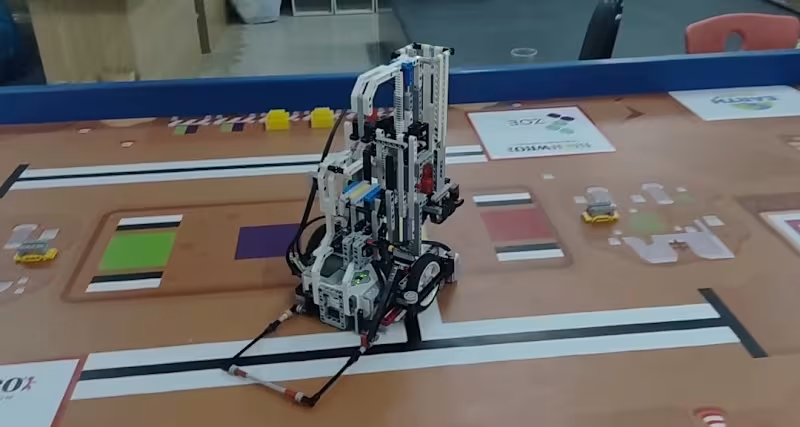
I designed and developed a custom robot for the WRO Senior 2024 competition. The project involved building and programming an autonomous robot to complete competition tasks, with a focus on mechanical design, sensors, motor control, and autonomous navigation.
1
62
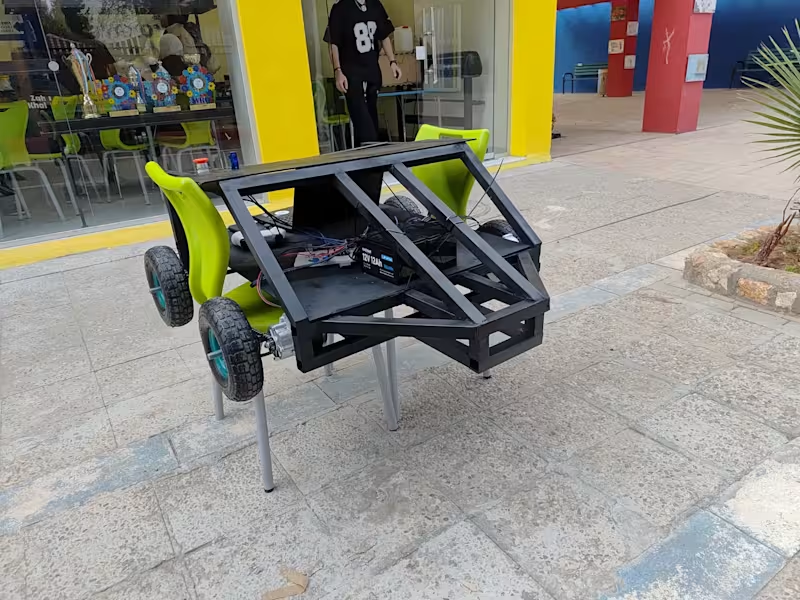
I designed and built a custom four-wheel rover powered by an ESP32 and four high-speed motors. The project included motor control, electronic integration, programming, and the development of the complete rover system.
1
73

Expert Mobile Engineer | Android & KMP
Expert Mobile Engineer | Android & KMP


Passionate UI/UX Designer | Senior Instructor


View more →